Three-axis Inertial Measurement Unit
R2026bImplement three-axis IMU
Three-axis Inertial Measurement Unit block
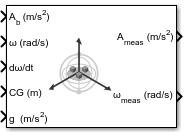
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Aerospace Blockset /
GNC /
Navigation
Description
The Three-Axis Inertial Measurement Unit block implements an inertial measurement unit (IMU) containing a three-axis accelerometer and a three-axis gyroscope.
For a description of the equations and application of errors, see Three-axis Accelerometer and Three-axis Gyroscope.
The Three-axis Inertial Measurement Unit block icon displays the input and output units selected from the Units parameter.
Examples
Lightweight Airplane Design
Address the technical and process challenges of aircraft design using the design of a lightweight aircraft.
Limitations
Vibropendulous error, hysteresis affects, anisoelastic bias, and anisoinertial bias are not accounted for in this block.
This block is not intended to model the internal dynamics of different forms of the instrument.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"aerolibnav/Three-axis Inertial Measurement Unit"
Example: add_block("aerolibnav/Three-axis Inertial Measurement Unit","myModel/myBlock",MakeNameUnique="on")
References
[1] Rogers, R. M., Applied Mathematics in Integrated Navigation Systems, AIAA Education Series, 2000.
Extended Capabilities
Version History
Introduced before R2006a

