Configure and Simulate LLC Resonant Converter Controller
R2026bIn this step of the LLC Resonant Converter Controller Design Workflow example, you can configure the plant model and controller gains for simulation. To get started, open the project and click the Configure and Simulate shortcut on the project toolstrip. The shortcut opens the live script so you can step through it..
In this stage you build the Simscape™ Electrical™ plant subsystem, configure the
voltage controller subsystem reference with default or custom proportional-integral (PI)
or 3-pole 3-zero (3p3z) gains, and validate the closed-loop response in simulation. The
gains produced here are written to ctrlData.mat and are the starting
point that every downstream stage of the project (frequency response estimation (FRE)
tuning, stability analysis, hardware-in-the-loop (HIL) testing, hardware FRE, and
algorithm export) consumes.
Configure Resonant Converter Plant
To make every downstream stage match your converter, first set the electrical
parameters of the plant. The resonant converter electrical circuit is implemented as
a plant model using Simscape Electrical and is parameterized through
resonantconvertersimdata.m, which calls ResonantConv
= PlantParameters('Converter100W');.
PlantParameters.m provides default LLC resonant converter
parameters. To characterize a different converter, add a new case to the switch-case
structure inside PlantParameters.m. Skip this section to continue
with the default 100 W configuration.
edit PlantParameters; % Skip this section to proceed further with the default converter plant data.
After you add a new case, open resonantconvertersimdata.m and
update the line below to select your custom converter name.
ResonantConv
                    = PlantParameters('Converter100W');
The resonant converter plant model is implemented as a subsystem reference, so any parameter change here propagates directly into the closed-loop simulation model.
Note: The converter parameters defined here are reused by every later stage (closed-loop simulation, default-gain estimation, stability analysis, and frequency response analysis), so a single edit reconfigures the entire workflow.
Configure Resonant Converter Controller
To regulate the output voltage of the LLC resonant converter, the subsystem
reference model at
~\ModelComponents\Controller\VoltageController.slx implements
a voltage controller that uses direct frequency control of the resonant tank.
The controller supports two gain sets (default gains and custom gains), and the
GainsSelector mask parameter picks between them at simulation
time. Choosing the appropriate gain source lets you compare an analytically derived
starting point against a hand-tuned or FRE-based design without editing the
controller model.
Default Controller Gains
For the default gain calculation, the Resonant Converter Gains
block uses the resonant converter parameters defined in the previous section and the
controller sample time. When ResonantConverterSim.slx finishes a
run, it writes these gains to ctrlData.mat, making them available
to every downstream stage.
Custom Controller Gains
For custom gains, the Resonant Converter Gains block reads the
values already stored in ctrlData.mat, so the controller runs
against your overrides instead of the defaults.
To override the defaults, use the code below to write your own PI or higher-order
compensator coefficients into ctrlData.mat. The
kivoltTs field stores the integral gain pre-multiplied by the
controller sample time, which lets the discrete-time integrator use a single
multiply.
prjPath = matlab.project.rootProject().RootFolder;
matFile = fullfile(prjPath, 'Data', 'ctrlData.mat');
load(matFile); % Loads the structure ctrlData
ctrlData.Custom.kpvolt = 1100; % Kp for PI Control
ctrlData.Custom.kivoltTs = 70; % Ki*Ts
ctrlData.Custom.numecoef = [1 1 1]; % Coefficients for Higher order compensators
ctrlData.Custom.dencoef =  [1 1 1];%  Coefficients for Higher order compensators
ctrlData.Custom.ctrltype = 1; % 1 for PI 2 for Higher order compensators
ctrlData.Custom.timestamp =  datetime;
save(matFile, 'ctrlData');
Set ctrltype to 1 for a PI compensator or
2 for a 3-pole 3-zero (higher-order) compensator. The
numecoef and dencoef fields are only used
when ctrltype is 2. After the save completes,
ctrlData.mat is the single source of truth for controller
gains in every downstream stage.
Note: The gains stored in
ctrlData.mat, whether default or custom, drive both the
simulation and the stability analysis.
Simulate the Model
To validate that the plant model and controller work together before touching
hardware, open and simulate ResonantConverterSim.slx. The
simulation model consumes the parameters loaded in the previous stages and the two
subsystem references: VoltageController and the converter plant.
VoltageController contains the Resonant Converter
Control Gains and Resonant Converter Controller
blocks. The plant subsystem selects between half-bridge and full-bridge LLC
topologies based on the PlantConfig field.
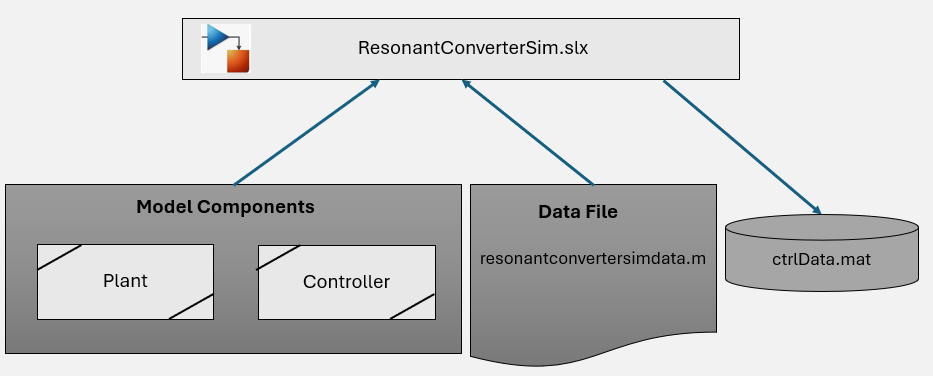
simmodel = ResonantConverterSim;
open_system(simmodel);
Run the open-loop simulation first to validate the plant model and the converter's electrical design. Confirm that the tank current, rectifier voltage, and DC output match your expectations. Then run the closed-loop simulation to validate the resonant controller design, the control gains, and the control-loop timing. Look for acceptable rise time, overshoot, and steady-state error at the reference voltage.
Note: To simulate a 3-pole 3-zero (3p3z)
compensator instead of PI, use
ResonantConverterSimHigherorder.slx. That model consumes the
higher-order controller gains computed by CalcLlcType3CtrlGains
and uses the same plant subsystem.
See Also
Topics
- Estimate Online Frequency Response of LLC Resonant Converter
- Verify Stability Margins and Analyze Sensitivity for LLC Resonant Converter
- Validate Controller with HIL Testing for LLC Resonant Converter
- Validate Controller Gains with Frequency Response Estimation on Hardware
- Export Controller Algorithm Custom Targets

