show
R2026bVisualize UAV Dubins path segment
Description
axHandle = show(pathSegObj)
Note
Plotting uses only the position and the yaw angle.
axHandle = show(pathSegObj,Name=Value)
Examples
This example shows how to calculate a UAV Dubins path segment and connect poses using the uavDubinsConnection object.
Create a uavDubinsConnection object.
connectionObj = uavDubinsConnection;
Define start and goal poses as [x, y, z, headingAngle] vectors.
startPose = [0 0 0 0]; % [meters, meters, meters, radians]
goalPose = [0 0 20 pi];
Calculate a valid path segment and connect the poses. Returns a path segment object with the lowest path cost.
[pathSegObj,pathCosts] = connect(connectionObj,startPose,goalPose);
Show the generated path.
show(pathSegObj{1})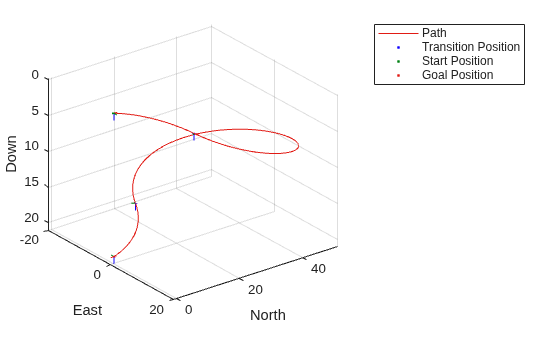
Display the motion type and the path cost of the generated path.
fprintf('Motion Type: %s\nPath Cost: %f\n',strjoin(pathSegObj{1}.MotionTypes),pathCosts);Motion Type: R L R N Path Cost: 138.373157
Input Arguments
Name-Value Arguments
Output Arguments
Version History
Introduced in R2019b

